Survey
* Your assessment is very important for improving the work of artificial intelligence, which forms the content of this project
* Your assessment is very important for improving the work of artificial intelligence, which forms the content of this project
Coriolis force wikipedia , lookup
Introduction to general relativity wikipedia , lookup
Bohr–Einstein debates wikipedia , lookup
Photon polarization wikipedia , lookup
Electromagnetic mass wikipedia , lookup
Newton's theorem of revolving orbits wikipedia , lookup
Anti-gravity wikipedia , lookup
Woodward effect wikipedia , lookup
Elementary particle wikipedia , lookup
History of subatomic physics wikipedia , lookup
History of special relativity wikipedia , lookup
Lorentz ether theory wikipedia , lookup
Relational approach to quantum physics wikipedia , lookup
Speed of gravity wikipedia , lookup
Lorentz force wikipedia , lookup
Centripetal force wikipedia , lookup
Equations of motion wikipedia , lookup
Relativistic quantum mechanics wikipedia , lookup
Time dilation wikipedia , lookup
History of Lorentz transformations wikipedia , lookup
Centrifugal force wikipedia , lookup
Mechanics of planar particle motion wikipedia , lookup
Classical mechanics wikipedia , lookup
Faster-than-light wikipedia , lookup
Work (physics) wikipedia , lookup
Newton's laws of motion wikipedia , lookup
Length contraction wikipedia , lookup
Four-vector wikipedia , lookup
Velocity-addition formula wikipedia , lookup
Special relativity wikipedia , lookup
Theoretical and experimental justification for the Schrödinger equation wikipedia , lookup
Time in physics wikipedia , lookup
Derivations of the Lorentz transformations wikipedia , lookup
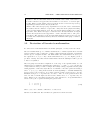
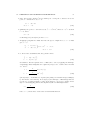
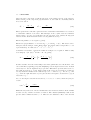
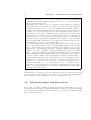
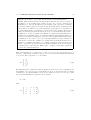
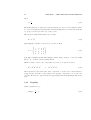
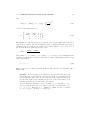
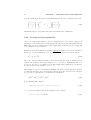
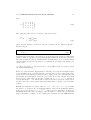
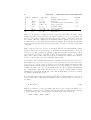
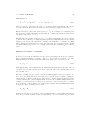
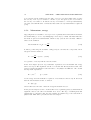
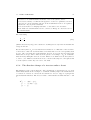
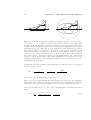
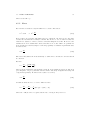
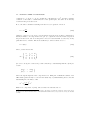
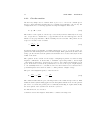
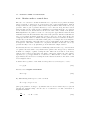
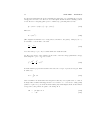
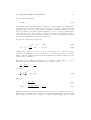
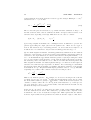
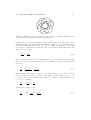
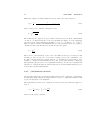
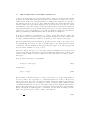
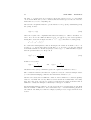
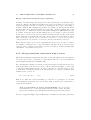
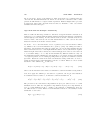
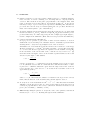
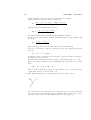
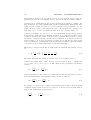
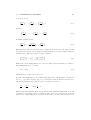
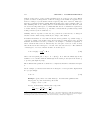
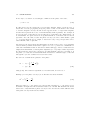
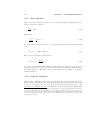
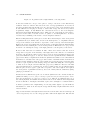
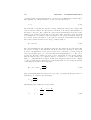
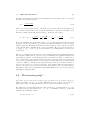
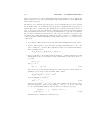
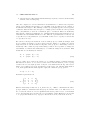
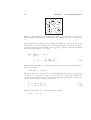
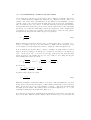
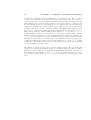
48 CHAPTER 3. THE LORENTZ TRANSFORMATION relationship to a 3-vector is more complicated: Aâ¡ dU dU =γ =γ dÏ dt µ ¶ dγ dγ c, u + γa dt dt (3.55) where, of course, γ = γ(u) and a is the 3-acceleration. Using dγ/dt = (dγ/du)(du/dt) with the γ relation (3.11) and1 du/dt = (u ·a)/u, we find dγ u ·a = γ3 2 . dt c (3.56) Therefore A = γ2 ³ u ·a c γ2, ´ u ·a 2 γ u + a . c2 (3.57) In the rest frame of the particle this expression simplifies to A = (0, a0 ) (3.58) where we write a0 for the acceleration observed in the rest frame. If one takes an interest in the scalar product U · A, one may as well evaluate it in the rest frame, and thus one finds that U · A = 0. (3.59) That is, the 4-acceleration is always orthogonal to the 4-velocity. This makes sense because the magnitude of the 4-velocity should not change: it remains a unit vector. 4-velocity is timelike and 4-acceleration is spacelike and orthogonal to it. This does not imply that 3-acceleration is orthogonal to 3-velocity, of course (it can be but usually is not). Using the Lorentz-invariant length-squared of A one can relate the acceleration in any given reference frame to the acceleration in the rest frame a0 : µ ³ ´2 ¶ u ·a ´2 4 ³ u ·a 2 γ u + a γ4 â γ + = a20 . c c2 1u (3.60) = (u · u)1/2 â du/dt = (1/2)(u2 )â1/2 (u · a + a · u) = u · a/u, or use (d/dt)(u2x + u2y + u2z )1/2 .