Survey
* Your assessment is very important for improving the work of artificial intelligence, which forms the content of this project
* Your assessment is very important for improving the work of artificial intelligence, which forms the content of this project
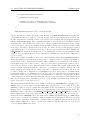
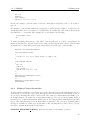
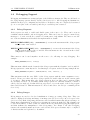
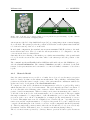
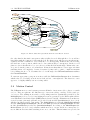
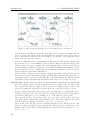
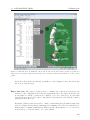
5.2. MOTION CONTROL B-Human 2010 Hip T orso T high HipOrthogonal F oot Figure 5.5: Visualization of coordinate frames used in the inverse kinematic. Red = x-axis, green = y-axis, blue = z-axis. The limbs of the leg and the knee form a triangle, in which an edge equals the length of the translation vector of HipOrthogonal2F oot (ltrans ). Because all three edges of this triangle are known (the other two edges, the lengths of the limbs, are fix properties of the Nao) the angles of the triangle can be computed using the law of cosines (5.16). Knowing that the angle enclosed by the limbs corresponds to the knee joint, that joint angle is computed by equation (5.17). c2 = a2 + b2 â 2 · a · b · cos γ γ = arccos lupperLeg 2 + llowerLeg 2 â ltrans 2 2 · lupperLeg · llowerLeg (5.16) (5.17) Because γ represents an interior angle and the knee joint is being stretched in the zero-position, the resulting angle is computed by δknee = Ï â γ (5.18) 69